Projects
Open source tools for UAV simulation and quadruped robot mapping and navigation.
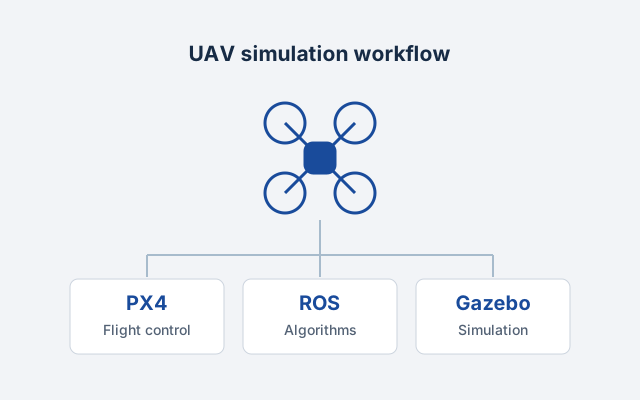
XTDrone
Lead Developer and Community Maintainer
A UAV simulation platform for developing and testing algorithms with PX4, ROS, and Gazebo.
Key contributions: Led version upgrades and plugin development, integrated new UAV features, and maintained documentation and the community.
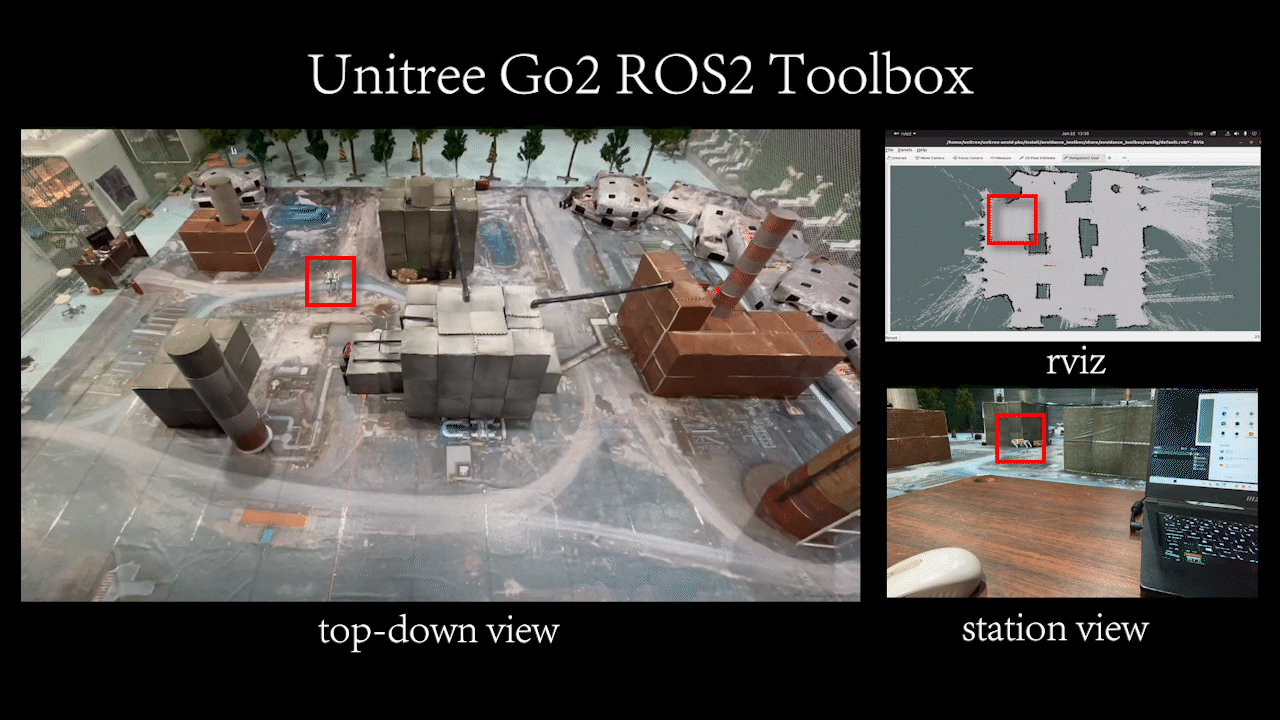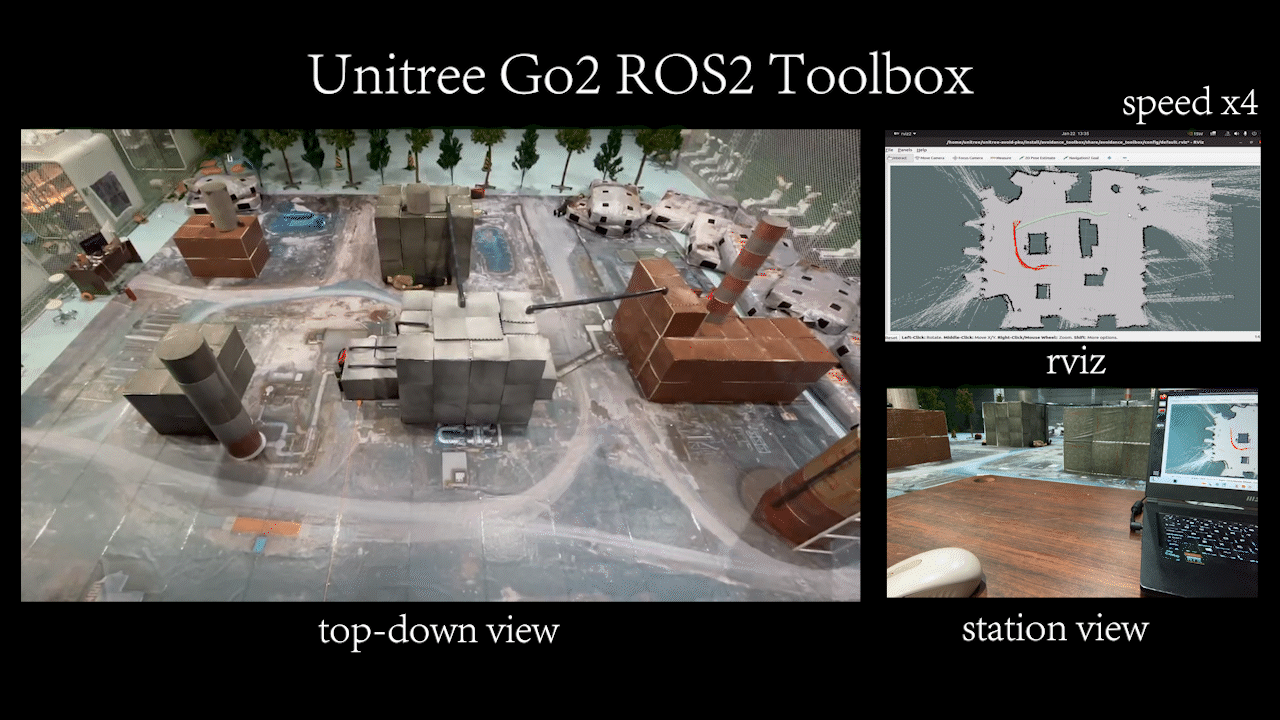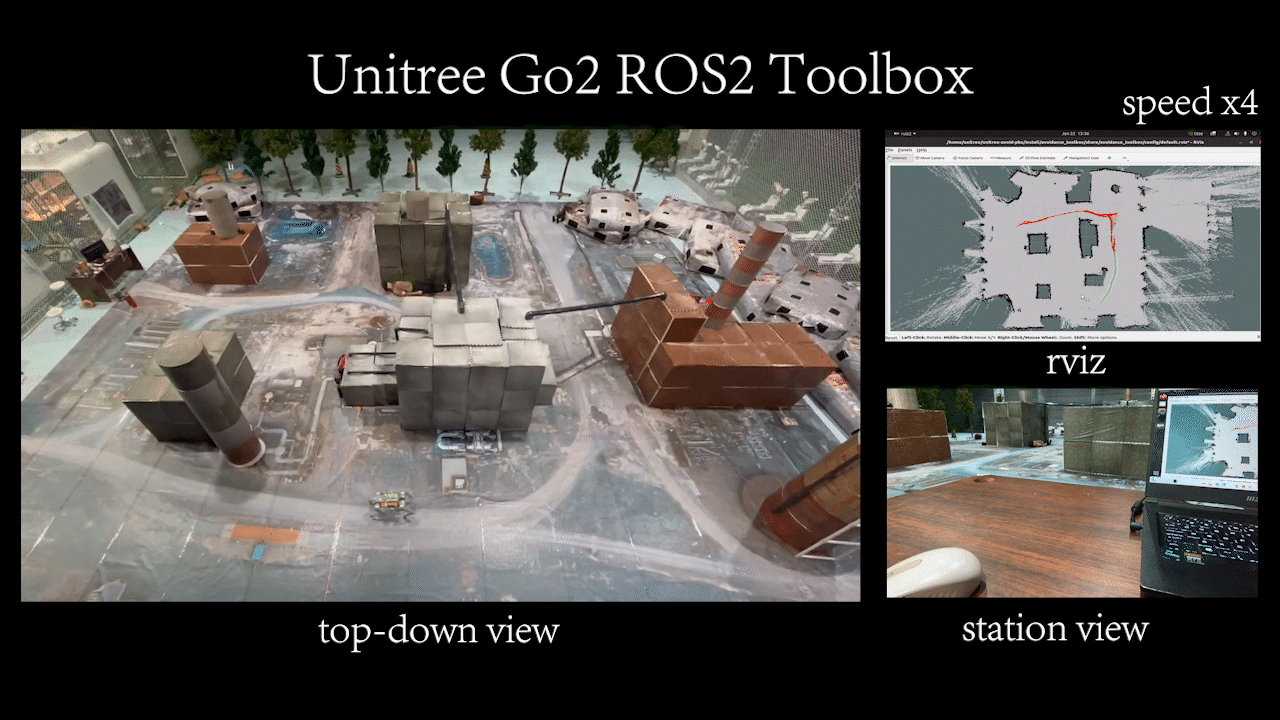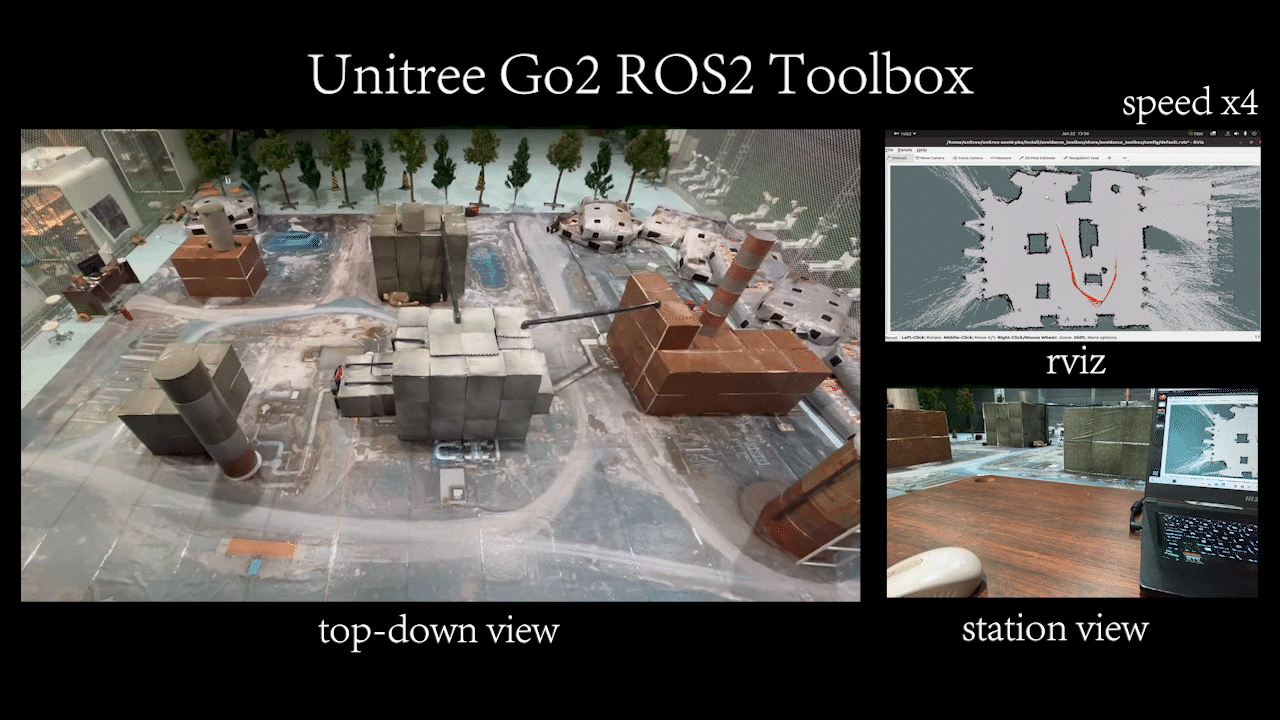
Go2 ROS2 Toolbox
Developer
Mapping and autonomous navigation tools for the Unitree Go2 EDU quadruped robot.
Key contributions: Integrated SLAM Toolbox and Navigation2, with LiDAR point cloud processing and camera support.